
Drives, servos, welders and controllers draw pulsed, unbalanced current. A sag from the utility trips the drives and stops the line. The panel records both the utility’s share of each disturbance and the plant’s own. A 2004 study by Lawrence Berkeley National Laboratory put the cost of power interruptions to U.S. electricity customers at about $80 billion a year in 2002 dollars. Industrial customers bore about $20 billion of it 64.
Executive summary
Correct the plant’s own share at the panel. Every disturbance arrives in two shares, one from the utility and one made inside the plant. The utility’s share stays in place 1,40.
- Sags. Voltage dips that stop drives in cycles. Correction removes the plant’s own reactive share of the drop, but it does not hold the voltage or keep a machine running through a sag 40.
- Drive panels. Six-pulse drives on motor control centers. Drives draw their current in pulses, and correction through the 23rd harmonic keeps the corrected loads’ harmonic current at the panel 1,40.
- Motors. Line-fed motors on unequal phases. Where a single-phase load on the same panel drives the unbalance, correction removes the panel’s share and the motor runs cooler 1,40.
- Controls and sensors. Controllers and sensors on 208Y/120 volt panels. The controller lowers the neutral current from the corrected loads to near zero by rating. The part of the neutral-to-ground voltage that current made falls with it 1,40.
A factory uses its electricity through many kinds of machine. Drives turn motors at variable speed. Servos position tools.
Compressors and chillers start across the line or on soft starters. Welders and presses pull current in bursts. Controllers and sensors watch the floor through small power supplies.
Four disturbances reach the product through those machines: a voltage sag, a distorted waveform, unequal phases and voltage between neutral and ground. Each one arrives in two shares. The plant makes its own share with its own current, through its own wires and transformer. This is the Consumption pillar. Nonlinear loads distort the waveform, and the plant’s share is the current its own machines draw.
Power quality promises are not new. Most came with a brochure and no measurement. The second share is where Software-Defined Electricity works. The VectorQ controller connects in parallel at a panel. It corrects the plant’s share in millionths of a second. The utility’s share stays, and this page says so at every step.
The problem
The load. Every industrial facility takes three-phase power, on a four-wire wye with ground or on a delta 1. Wye circuits carry 480 or 208 volt three-phase loads and 277 or 120 volt single-phase loads 1. The 480 volt panels carry the drives, the compressor and chiller starters, the welders and the presses.
A machine tool takes one 480 volt feed. Its own transformer makes the servo and control voltages inside the cabinet. Lighting, receptacles and stand-alone controllers sit on 208Y/120 volt panels.
A drive rectifies the incoming AC to DC, then inverts the DC back to AC at an adjustable frequency 1. A programmable logic controller (PLC) converts AC to low-voltage DC through a high-speed switching supply 1. In a fab, each process tool sits behind its own power supply, and often behind a UPS or a sag corrector on the tool power 23,24. On the facility side, the chillers, pumps, scrubbers and cleanroom fans run from ordinary motor control centers.
Signs the electricity in a plant is uncontrolled. An operator has seen each of these on the floor. Each has a chain below, with its number and its source.
- A drive that trips on a dip the lights barely showed, and a restart nobody scheduled.
- A contactor that drops out on a sag and takes the compressor with it.
- A transformer that runs hot at a load well under its nameplate.
- A motor on a line-fed starter that runs hotter on one phase than on the other two.
- A PLC or a sensor that throws data errors with no fault anyone can find.
- A capacitor fuse that blows, or a relay that trips, for no reason anyone has named.
- A reactive charge on the bill, or billing demand above the kilowatts the plant used.
The rule. The voltage at a panel is the utility’s voltage minus the panel’s own current times the impedance between the two 1. V_panel = V_utility minus I × Z. TM 5-689 states the harmonic case, E = I × Z: the drop across the source is proportional to its impedance 1. The rule holds at every frequency and for each sequence 1,34. So the same rule splits a sag, a distortion and an unbalance into two shares.
The load-driven share is the panel’s own amperes times the plant’s own ohms. The utility-delivered share arrives on the service conductors.
In a transformer’s reactance, reactive current drops the voltage in phase, so the reactive amperes set the size of the drop 34. Working current in the same reactance drops the voltage in quadrature and changes its size at second order only 34. In a long cable’s resistance, working current also drops the voltage in phase. The correction leaves this share.
The arithmetic. Take an illustrative 60 kilowatt panel at 0.85 displacement power factor on 480 volts. The panel draws 70.6 kilovolt-amperes and 85 amperes per phase 34. Of those, 72 amperes do work and 45 amperes are reactive 34.
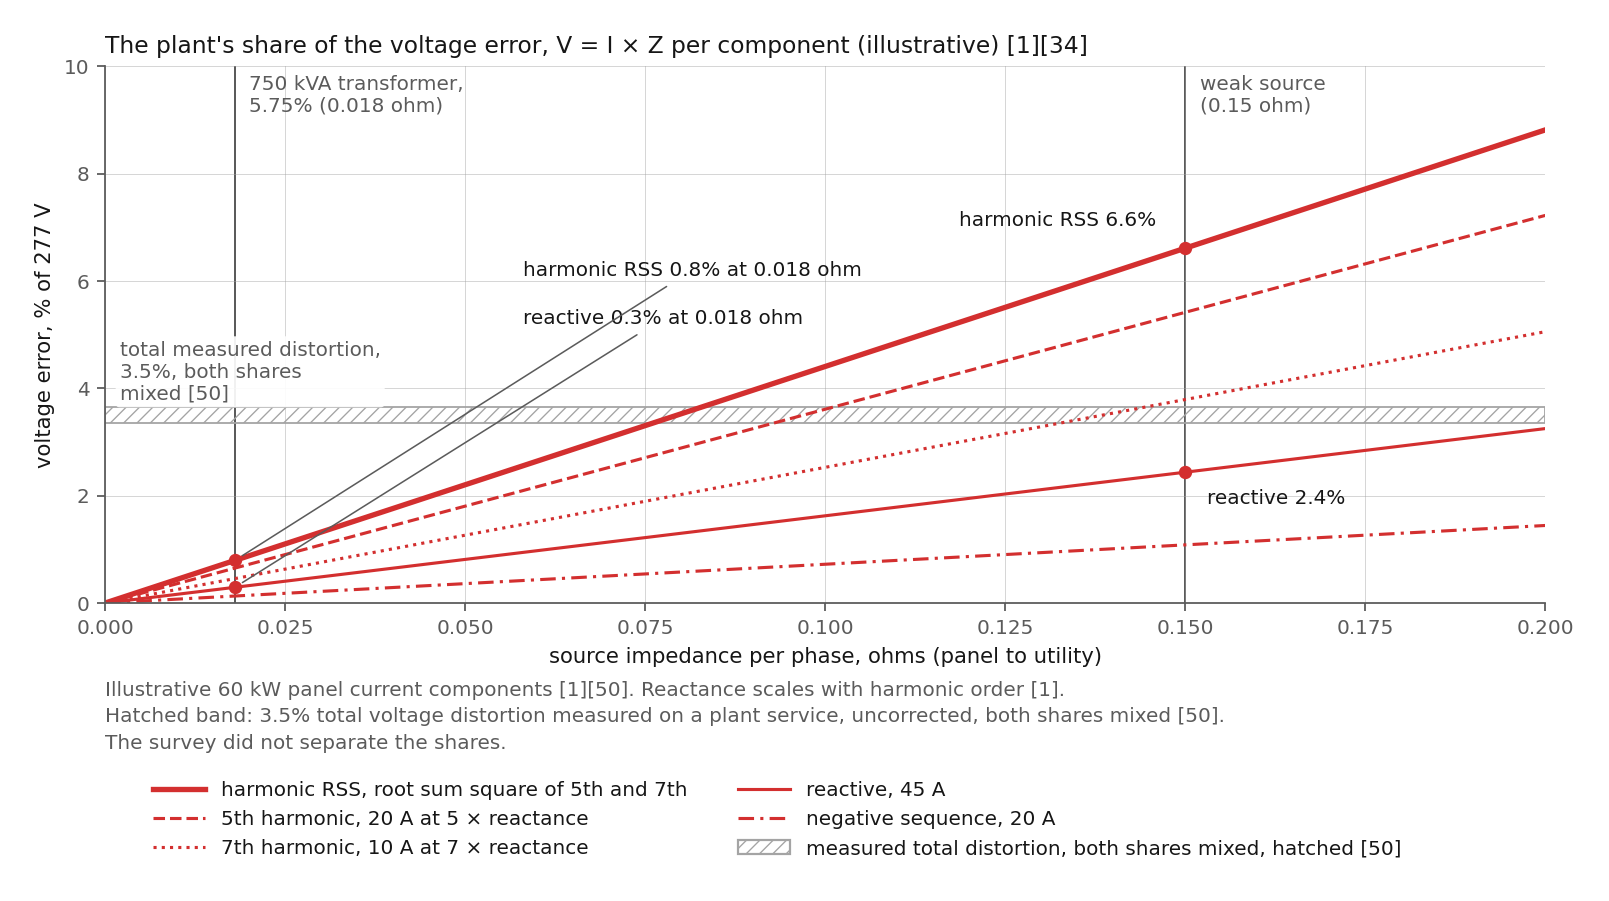
A 750 kilovolt-ampere transformer at 5.75% impedance presents 0.018 ohms per phase at 277 volts. The 45 reactive amperes drop 0.8 volts across the transformer, 0.3% 1. A weak source of 0.15 ohms takes 6.7 volts from the same amperes, 2.4% 1.
The share the panel’s own loads create is large on a weak service and small on a stiff one. The arithmetic is linear and illustrative. One plant we assessed fed its machines through a long feeder run to a switch room, and longer runs to the floor 51. On such a feeder, the resistive share of the drop belongs to the working current and stays. Our network analysis measures the two shares at each panel, with correction on and off.
Four chains. Each chain below runs in the same order: the mechanism, a magnitude, the consequence on the floor, a published cost and the one link the correction changes.
Chain one: the sag
The mechanism. Sags come from switching heavy loads onto the line and from faults the utility clears 1. A motor start draws heavy inrush current, which drops the voltage for a short period, and regulation takes a definite period to recover 1. The plant’s own share of a motor-start sag is the start current times the plant’s own impedance 1. The utility’s share comes from a fault on the feeder, and the plant’s wires carry the sag in 1.
An urban customer sees one or two interruptions a year and over twenty sags 28. At one industrial facility a measurement campaign logged 72 sags, 36 of them between 10 and 100 milliseconds, and none over one second 29.
The trip. Deep enough sags pass through internal DC power supplies 1. Equipment that initializes at startup initializes again after a severe sag 1. Much electronic equipment shuts down and stays down if the voltage drops below a limit for more than a few milliseconds 1.
TM 5-689 names the worst case: part of an integrated system restarts after the sag and the rest does not 1. Inside a drive or a tool power supply, the DC bus decides.
The energy stored on the bus is one half C V squared 25. On an interruption at constant power the hold-up time is t = C (V_nominal² minus V_trip²) / (2 P) 25.
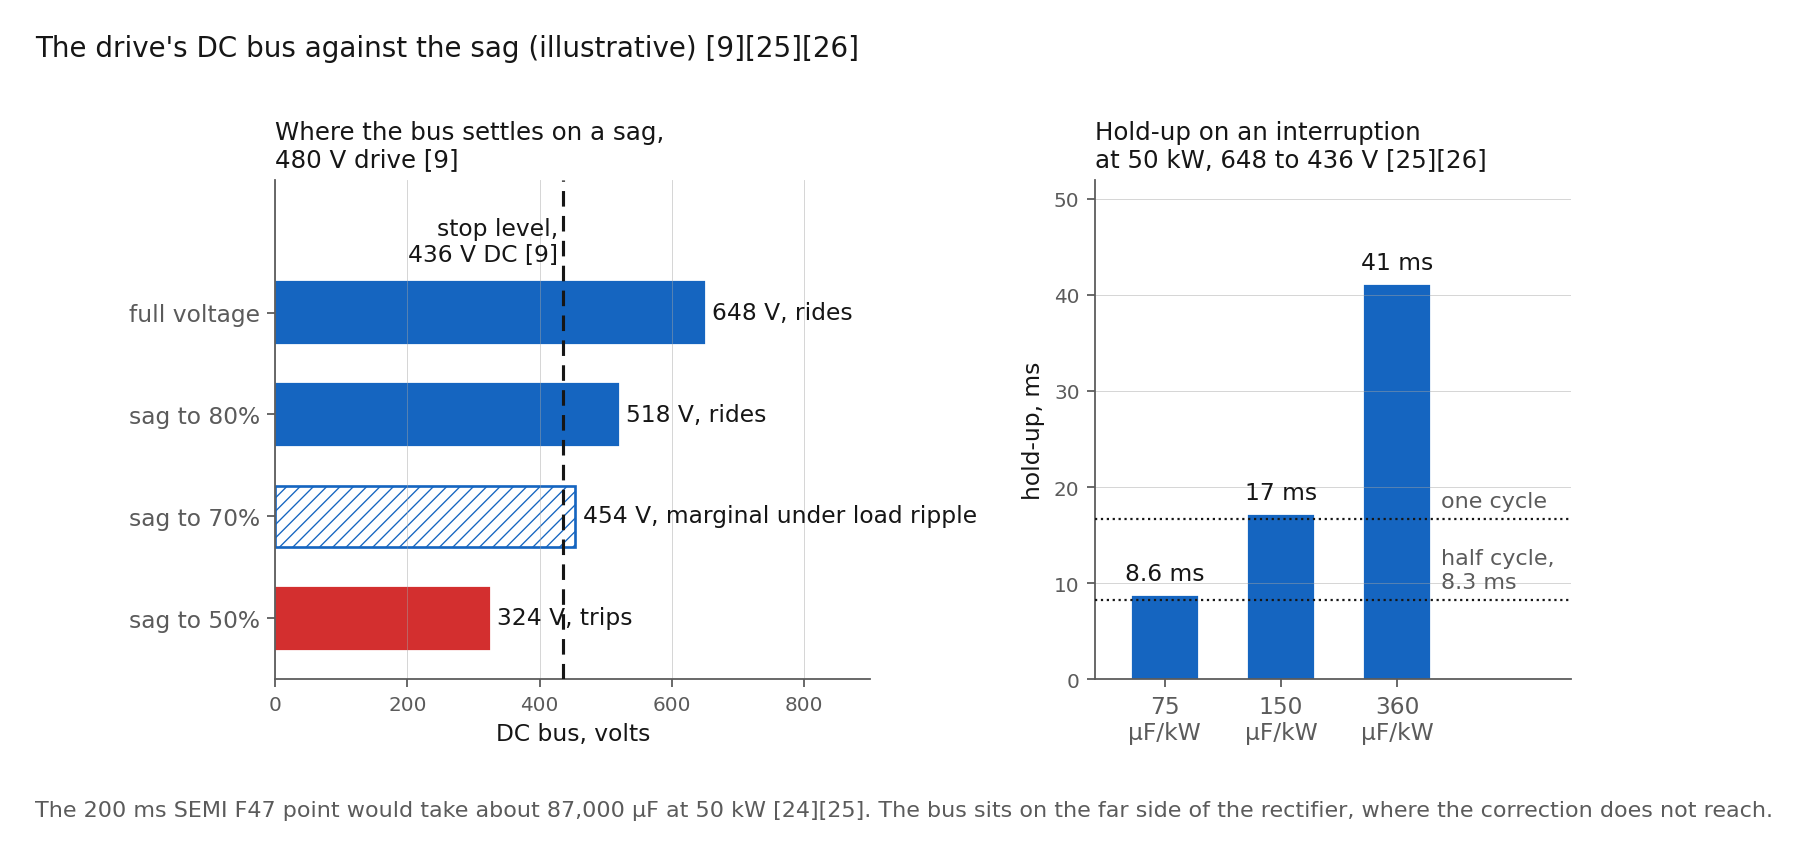
Take an illustrative 480 volt drive at 50 kilowatts with its bus near 648 volts DC. One drive maker’s manual says that a drive keeps running through a mains dropout until the DC link falls to its stop level 9. The level typically sits 15% below the lowest rated supply voltage 9. On a 380 to 480 volt unit the level sits near 436 volts DC, by the arithmetic above 9.
Typical drive capacitance runs 75 to 360 microfarads per kilowatt 26. At 150 microfarads per kilowatt the bus holds 862 usable joules and rides 17 milliseconds, about one cycle 25,26. The range runs from half a cycle to two and a half cycles 25,26. To ride the 200 millisecond SEMI F47 point at 50 kilowatts, the bus would need about 87,000 microfarads 24,25. Hold-up time falls in inverse proportion to load 25.
A tested drive tripped when its DC link fell to 288 volts on a 0.2 second interruption 26. Some drives ride a short loss on the kinetic energy of the rotating motor 10. The bus sits on the far side of the rectifier. The correction does not reach it.
The shallow sag. The drive bus rides the shallow sags and loses the deep ones. On a sag, unlike an interruption, the rectifier keeps conducting once the line peak exceeds the bus voltage.
At 80% the bus settles near 518 volts, above the 436 volt stop level 9. At 70% the bus sits near 454 volts, marginal under load ripple 9. At 50% the bus falls to 324 volts, below the level 9.
On a shallow sag, the auxiliaries decide. A NEMA AC contactor rides through to about 85% voltage and a DC contactor to about 80% 12. Electromagnetic relays hold through sags to between 48 and 74% of nominal and drop out 5 to 28 milliseconds after the voltage falls below their threshold 59. In tests of semiconductor tools by the Electric Power Research Institute (EPRI), emergency-off circuits caused the shutdown in 47% of the tests 23. Sags to 78% of nominal lasting under one cycle shut down tools with sensitive relays 23.
On a line-fed motor, torque falls with the square of terminal voltage 3,15. A sag to 80% leaves 64% of torque, and a sag to 50% leaves 25% 15. At those contactor thresholds, the contactor drops out before the torque loss matters. So a compressor’s sag chain is a contactor chain more often than a torque chain 12,15.
The stop and the cost. A drive with ride-through disabled faults 15 milliseconds after power loss 11. Drives with automatic restart wait 30 to 60 seconds for the circuit to stabilize 12.
A questionnaire of 33 Brazilian companies in twelve sectors, run in 2019 and published in 2021, put a sag or short-interruption shutdown at 7,365 dollars per event, self-reported 20. Automotive plants reported 6,000 to 13,048 dollars per event 20. The survey carries no semiconductor plant 20.
A U.S. meta-study of 34 survey datasets from ten utilities put a momentary interruption at 12,952 dollars per event for medium and large commercial and industrial customers 21. The figure is in 2013 dollars.
The primary records of a fab stopping are outage records, not sag records. NXP reported to the SEC a full shutdown of two Austin fabs from 2021-02-15 to 2021-02-27 after loss of utilities 33. NXP lost about one month of wafer production, with about 100 million dollars of second-quarter revenue at stake 33. We found no primary record of a sag stopping a fab with the loss stated. So this page attaches no fab dollar figure to a sag.
The link the correction changes. Inside its operating band of plus or minus 15% on voltage, the controller corrects the load current of its panel 40. The one link the correction changes is the plant’s own share of the drop 1,40. The share is the corrected loads’ reactive and harmonic current times the plant’s own impedance, within 60 amperes per phase 1,40. A motor start draws six to seven times full-load current, far above 60 amperes, so in a motor-start sag the term is small 16,40.
Every SEMI F47, IEEE 1668 and IEC 61000-4-11 test point sits below 408 volts on a 480 volt bus, below the band 6,7,24,40. Our product specification, R034B, does not state behavior below the band 40. We state the behavior in writing before a pilot.
The controller does not hold the voltage, does not ride through and does not keep a machine running through a sag 40. The controller does not replace the sag corrector, the UPS, the drive’s ride-through setting or the restart logic 40. The drive bus, the contactors, the relays and the tool’s own supplies decide whether the machine stays on.

Chain two: harmonic voltage distortion
The mechanism. A static converter draws harmonics of order n = kp ± 1 1,14. A six-pulse drive draws the 5th, 7th, 11th, 13th, 17th, 19th and 23rd 1. The harmonic current through the source impedance distorts the bus voltage, E = I × Z per order, and reactance rises with frequency 1. Every other machine on the bus then sees the distorted voltage 1.
Motors are linear loads. On distorted voltage, a motor draws harmonic current, which heats its laminations and windings 1. The motor overheats unless derated. The fifth harmonic affects motors in particular 1.
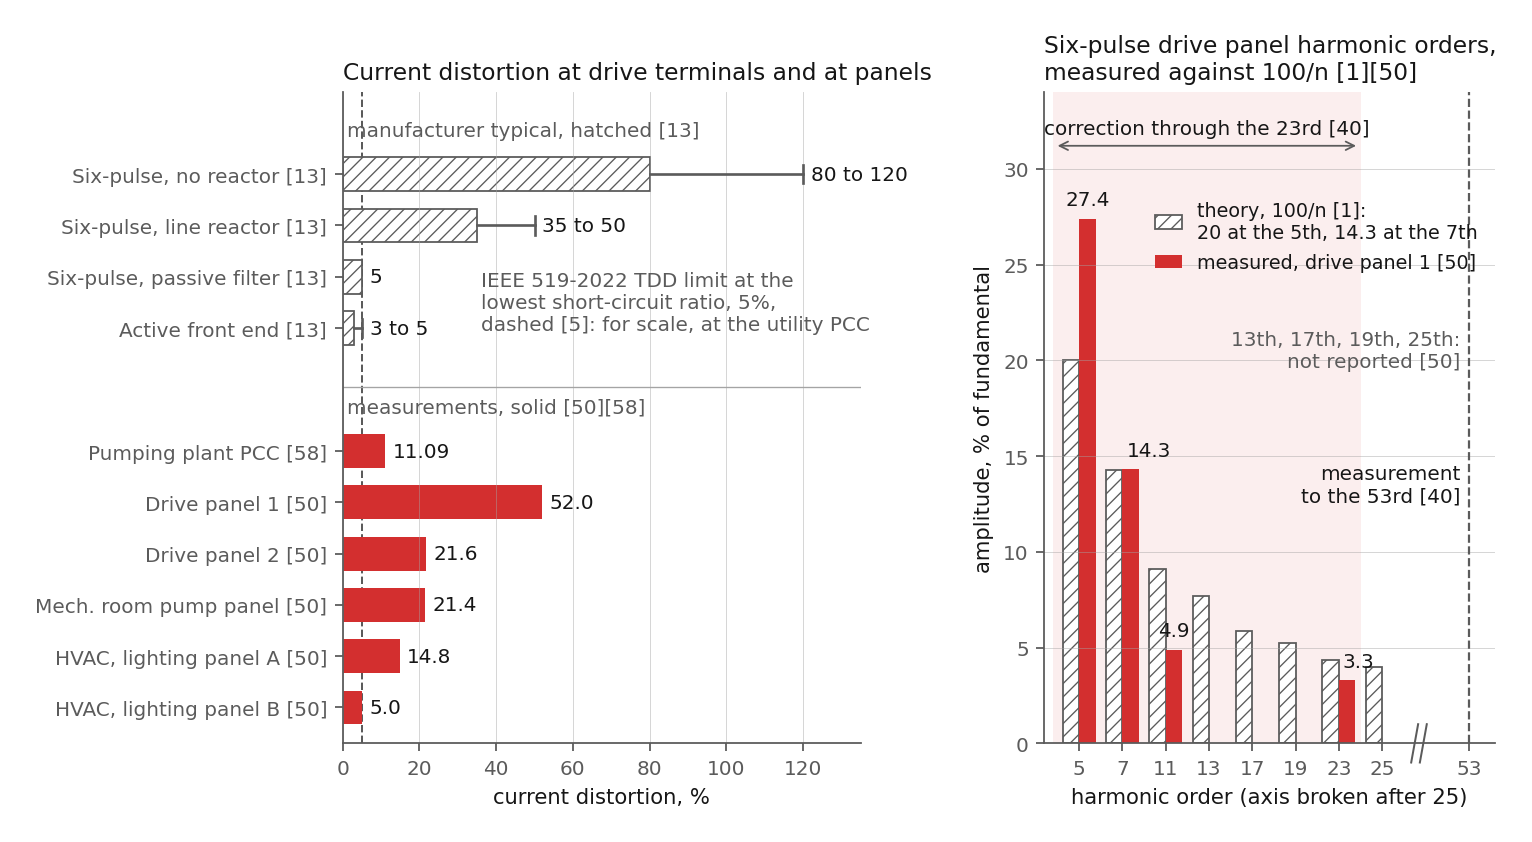
The measurements. We have surveyed a 480Y/277 volt plant service with a survey-grade analyzer 50. On a 225 ampere panel feeding six-pulse drives, a 57 second unfiltered recording read 52% current distortion 50. The orders read 27.4% fifth, 14.3% seventh, 4.9% eleventh and 3.3% twenty-third 50. The report states an average voltage distortion of 3.5% across the six panels 50.
The recordings ran 17 seconds to 15 minutes with a Class S instrument, at about a sixth of the plant’s stated demand 35,50. The report treats its IEEE 519 comparisons as a screening 50. IEEE 519-2022 sets 8% total and 5% per order for voltage on buses of 1 kilovolt and below 5. For current the standard sets 5 to 20% total demand distortion by short-circuit ratio 5.
The consequence. Harmonic current raises hysteresis, eddy current and skin effect losses 1. Transformers loaded under 70% of rating have shut down on over-temperature 1.
One equipment maker lists false tripping of branch circuit breakers, metering errors, communication errors and equipment malfunctions 54. The K-factor carries the harmonic heat into the transformer rating 55. Older average-sensing relays fail to trip on overcurrent or trip unnecessarily 1.
The literature puts the motor temperature rise from harmonics at about 4 to 6 degrees Celsius 17. Each 10 degree Celsius rise halves winding insulation life 2,18. On a drive-fed machine the motor sees the inverter, not the bus, so its torque ripple belongs to the inverter 1.
We found no open study linking supply distortion to surface finish or dimensional error on a machine tool. So the chain on this page stops at the motor’s heat and the drive’s input.
The link the correction changes. Correction runs through the 23rd harmonic 40. Within the 60 ampere budget, the controller supplies the corrected drives’ 5th through 23rd at the panel. Those orders no longer cross the plant’s transformer 40. The bus distortion from those loads falls in proportion 1.
On the illustrative panel, 20 amperes of fifth and 10 of seventh make about 0.8% distortion through 0.018 ohms, root sum square 1. Through 0.15 ohms the same amperes make about 6.6% 1.
The 3.5% our survey read mixes both shares, and no correction ran to separate them 50. The background distortion the utility delivers stays 1. The 25th and above pass uncorrected, and the controller measures them to the 53rd 40.
The drive’s switching frequency, selectable from 1 to 16 kilohertz, sits on the motor side of the DC bus 9. Supraharmonic emission between 2 and 150 kilohertz stays with the drive’s electromagnetic compatibility (EMC) filter under IEC 61800-3 37,63. The controller is a Class A switching converter and adds its own emission above the 23rd order 40.
Chain three: unbalance
The mechanism. Percent voltage unbalance is 100 times the largest deviation of a line voltage from the average, divided by the average 2. Unbalanced current through the source impedance makes unbalanced voltage, by the same rule, phase by phase 1,52. The Department of Energy’s tip sheet lists the causes 2.
Unevenly distributed single-phase loads and faulty power factor correction equipment sit inside the fence 2. An unbalanced utility supply, an unbalanced transformer bank, an open primary conductor and a single-phase ground fault sit outside 2. Welders and single-phase process heaters on a 480 volt panel are the plant’s own share.
The magnitude. Current unbalance runs as much as 6 to 10 times the voltage unbalance on a line-fed motor 2. NEMA MG 1 rates a polyphase motor for 1% unbalance at the terminals, and the tip sheet derates above 1% per NEMA’s curve 2,3. NEMA does not recommend operation above 5% 3. The tip sheet puts the added temperature rise at 2 × (percent unbalance)² 2.
Our survey read 10.7% current unbalance on one HVAC and lighting panel and 11.2% on another utilities panel, against 0.24 and 0.22% voltage unbalance 50. The current unbalance came from the single-phase loads on those panels. Through the 1,000 kilovolt-ampere source the panels’ own unbalanced current made a few hundredths of a percent of voltage unbalance 1,50. The utility delivered most of the 0.22% 50.
The consequence. Unbalanced current raises the motor’s losses and runs it hotter 2. A line-fed bench motor under 2% voltage unbalance carried a pulsating torque at twice line frequency of 15.7% of rated torque, with a 0.3% subharmonic present 19. The pulsation raised measured vibration to 1.58 millimeters per second 19.
Supply unbalance reaches a drive-fed motor only through the rectifier, as ripple on the DC bus and as unequal rectifier current on the line side. The consequence on the floor is a hotter compressor, chiller or fan motor, an earlier winding failure and a trip on the overload.
The link the correction changes. The controller transfers the difference between phases at the panel and holds the source current within 20% of average by rating 40. The balancing removes the I × Z share of unbalance the panel’s own single-phase and unequal loads create, down to the rated residual 1,40,52. Our two records read tighter than the rated residual 40,44,62.
On a 208Y/120 volt panel of single-phase loads the plant’s share is the larger term. The utility’s share comes down the line, within the 3% ANSI C84.1 asks of supply systems, and stays 2,4.
Phase balancing at the panel is the wrong tool for the utility’s share. The arithmetic sits in Why SDE below.
Chain four: neutral-to-ground and common-mode voltage
The mechanism. Third-harmonic currents from the three phases arrive in the neutral in step and add, and the same holds for the 9th, 15th and 21st 1. Unequal single-phase loading returns the difference on the neutral 1. The neutral current times the neutral’s impedance is a voltage between the panel’s neutral bar and ground, the rule once more 1.
TM 5-689 records the mechanism from the equipment side 1. Multiple points of grounding at slightly different potentials drive small ground currents, which appear as noise and cause errors in computation 1. A potential difference between the ends of a grounding conductor connecting two pieces of equipment makes data errors possible 1.
A drive adds a second source. The inverter’s common-mode voltage steps between plus or minus one sixth and plus or minus one half of the DC bus voltage at each switching edge 30. Edges exceed 5 kilovolts per microsecond without countermeasures 30. The common-mode current returns through the motor’s frame and the grounding system 30.
The consequence. A utility note lists the equipment common-mode currents affect: control signals, encoder feedback, PLC links, and ultrasonic, vision, weight and temperature sensors 31. IEEE 1100-2005, now inactive, treated ground loops and high-frequency noise on the grounding system as disruptors of logic and communication 32. We cite that standard as history.
We found no 2020 to 2026 study measuring an error rate on a fieldbus against neutral-to-ground voltage. The chain stops at the mechanism and the equipment list.
The link the correction changes. On a 208Y/120 volt or 480Y/277 volt panel, the controller lowers the neutral current from the corrected loads to near zero by rating 40. The reduction covers the fundamental difference by balancing and the triplen sum by correction through the 23rd 40. The neutral-to-ground voltage the corrected panel’s own neutral current made across its own neutral conductor falls with the current 1,40.
Neutral-to-ground voltage arriving from an upstream shared neutral, an improper bond or a ground loop between two machines stays 1. The neutral current between the panel and each machine stays, so the machine’s own receptacle keeps the branch-circuit share 1. The common-mode voltage a drive’s inverter puts on the motor cable stays with the drive, its filter and the cable’s shield 30,31,37. A 480 volt delta system carries no neutral current to correct 40.

Path one, today: motor control centers, drives, starters and capacitors
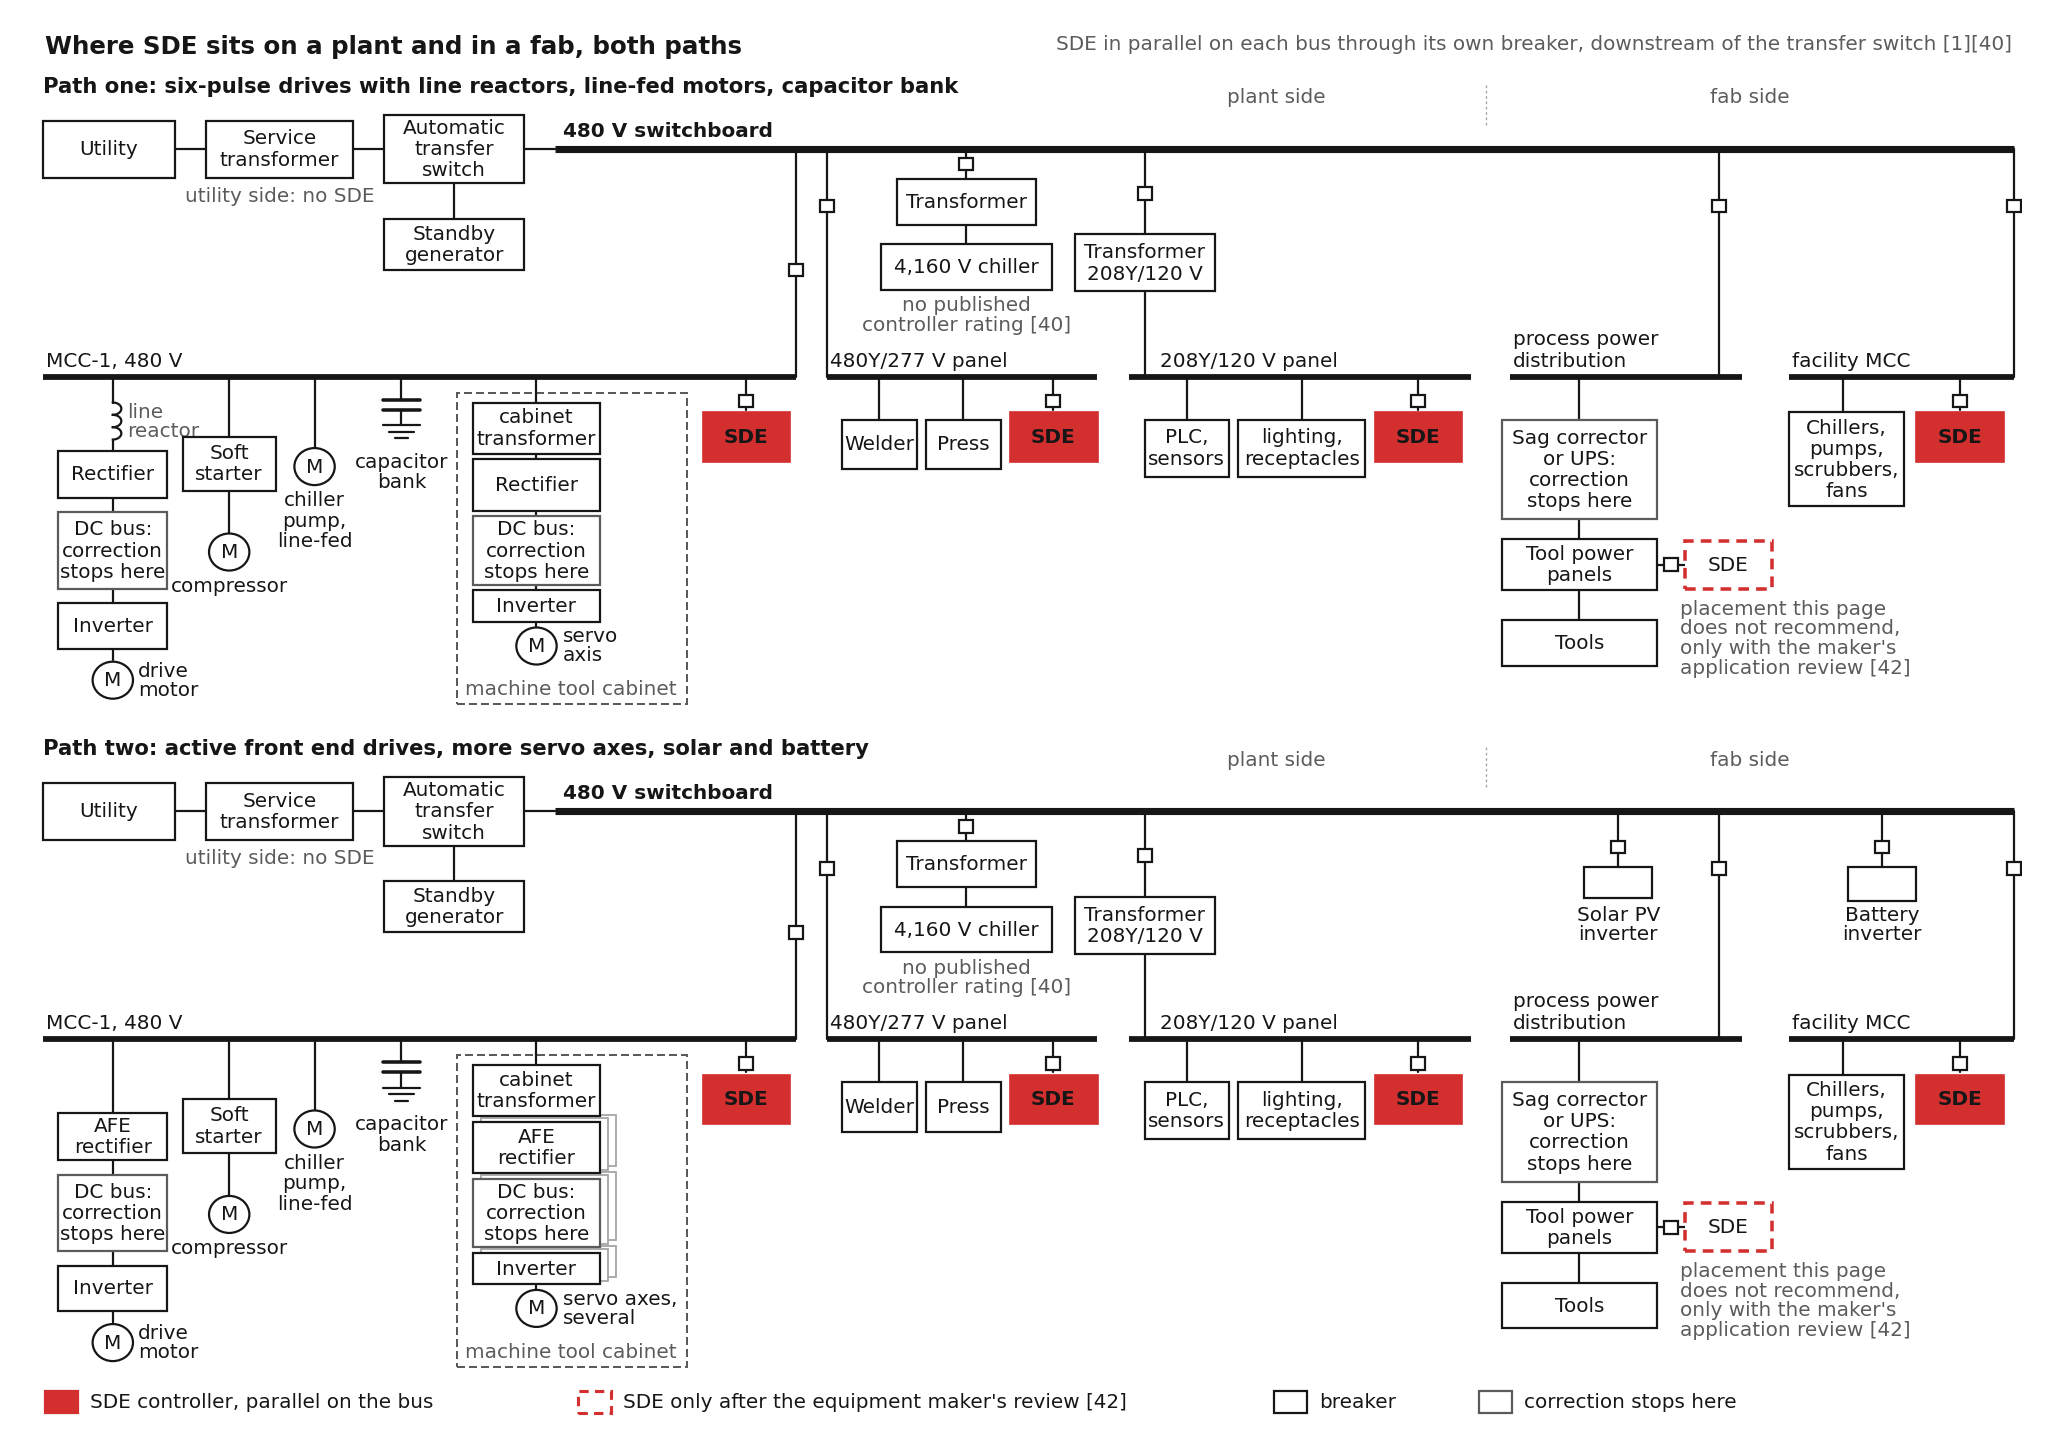
Most plants run this way today. A utility service feeds 480 volt switchboards, and a standby generator feeds life safety and selected process loads through a transfer switch 1. TM 5-689 holds the switch to one sixth of a second or less 1. Motor control centers feed drives behind line reactors, soft starters on the compressors and across-the-line starters on the fans and pumps 13,15.
Capacitor banks trim the power factor for the tariff, K-rated transformers carry the harmonic heat and tuned filters sit on the worst drive panels 1,38,54. The PLC holds the restart logic.
The transfer and the generator. A standby generator has 5 to 100 times the sub-transient reactance of the utility transformer, so nonlinear loads react entirely differently on a generator 1. ISO 8528-5 allows a class G2 set a 10% transient frequency drop and a 20% voltage drop on a load step 49. Those swings pass outside the controller’s 0.5% frequency band for seconds 40,49. We state the controller’s behavior on the generator in writing before a pilot.
Motor starting. NEMA puts locked-rotor current at 600 to 700% of full load 16. Take an illustrative 100 horsepower compressor on a 480 volt panel with a full-load current of 120 amperes. Across the line the start draws 720 to 840 amperes 16.
A soft starter holds the start near 3 to 4 times rated current, 360 to 480 amperes 15. The trade-off is lower torque 15.
The controller does not reduce a motor’s starting current. That current is the motor’s own. A VectorQ5 supplies at most 60 amperes per phase, so the rest of the start passes uncorrected 40. On the 750 kilovolt-ampere transformer, 720 amperes drop 13 volts, and 60 of those amperes make 1.1 volts, 0.4% of 277 1,40. The start belongs to the motor, the soft starter, the drive’s current limit and the motor-starting study 48.
What the controller does cover. On the illustrative 60 kilowatt panel, one VectorQ5 supplies the 45 reactive amperes per phase, inside its 60 ampere rating 40. The arithmetic assumes harmonic current shares the budget as a root sum of squares 34,40. About 40 amperes then remain for the 5th through the 23rd 40.
The transformer or the generator then carries 72 amperes per phase from those loads, plus the controller’s own draw 40. The arithmetic is linear, illustrative and steady state.
Our bench test on a compressor, a 460 volt motor load, points the same way as the arithmetic 43. With the controller powered off, the panel read 0.77 power factor and 5,659 volt-amperes reactive 43. With the controller idle, it read 0.82 and 4,852. Corrected, it read 1.00 and 488 43. Average current fell from 9.93 amperes idle to 8.25 corrected 43.
Active power at the connection ran 6,992 watts idle and 7,066 watts corrected, with the controller’s draw inside the reading 43. We claim no energy saving from the test. The idle controller also raised average current distortion from 3.27 to 4.96% at this 10 ampere load. Correction read 4.21% 43.
Welders and presses. A resistance welder draws current in bursts, and a press motor recharges its flywheel in cycles 36. The panel voltage flickers at the rate of the work 36. IEEE 1453 sets the practice for flicker, measured as the short-term severity Pst by the IEC 61000-4-15 flickermeter 36. Pacific Power’s standard puts the Pst compatibility level at 1.0 on low and medium voltage 36.
The plant’s own share of each flicker step is the welder’s reactive current times the plant’s own impedance 1. The controller responds to a change in load current in under 100 microseconds and supplies the reactive and unbalanced share of the burst within 60 amperes per phase 40,41. A large welder draws far more. So our network analysis records the welder’s current, and the controller covers the share within rating 40.
Capacitor banks and tuned filters. Plants carry fixed or switched capacitors for the utility’s power factor clause 1,38,39. Source inductance resonates with the bank at a frequency that one of the plant’s harmonic sources excites 1. The resonance amplifies the harmonics, and the source no longer limits them 1. The parallel resonance order is the square root of the short-circuit megavolt-amperes divided by the bank’s megavolt-amperes reactive 1.
Take the illustrative 750 kilovolt-ampere transformer, about 13 megavolt-amperes short circuit, and a 300 kilovolt-ampere-reactive bank. The resonance lands at the 6.6th order, between the 5th and 7th of every six-pulse drive on the bus 1.
An engineer tunes a filter for one load and one source impedance. A change of load, source or location degrades its performance 1. A bank and a tuned filter are analog compensation: fixed parts, chosen once, that cannot follow the load from cycle to cycle. The controller corrects the current digitally, from its own measurement, and follows the load as it changes.
A bank or a filter on a corrected panel is a coordination question, not a benefit. The controller’s current transformers sit on the panel’s incoming conductors, so a bank downstream reads as load current 40. R034B states that a second capacitor bank or active filter on an installation requires the coordination to be re-engineered 40. The network analysis records the bank, its switching steps, any detuning reactor and any filter, and decides. We do not promise the bank or the filter comes out.
Where the controller connects. A VectorQ5 connects in parallel on a 480Y/277 volt motor control center bus or panel 40,42. A VectorQ2 connects on a 208Y/120 volt panel 40. The connection runs through the controller’s own breaker, with a three-phase, neutral and ground cable 40.
R034B specifies a 50 ampere dedicated breaker, and the figure is under revision against the VectorQ5’s 60 ampere rating 40. The conductor, the overcurrent device and the arc-flash label follow the electrical code and the plant’s coordination study 56.
Whichever source feeds the motor control center through the transfer switch carries the corrected current, inside the band. On a drive, the correction sees the rectifier’s current on the line side, on the panel side of the drive’s line reactor 1. The motor’s own current and the drive’s output stay on the far side of the DC bus 1. On a soft-started or across-the-line motor, the motor’s running current lands on the panel directly.
On a UPS or sag-corrector output, the controller becomes a second fast converter on the tool bus. We do not recommend that placement. The UPS or sag-corrector maker’s application engineer reviews the pairing before a pilot 42. The device keeps its output voltage loop, its current limit and its transfer logic.
Coverage. One controller corrects one panel and reaches no other panel’s loads 46. Coverage scales with controller count and rating, and the network analysis sizes each panel. The VectorQ2 is rated for 208 volt panels up to 60 kilowatts and 9 kilovolt-amperes reactive at 50 amperes per phase 40. The VectorQ5 covers 480 volt panels up to 120 kilowatts and 60 kilovolt-amperes reactive at 60 amperes per phase 40.
On the VectorQ5 the ampere rating binds: 60 amperes at 277 volts per phase is 50 kilovolt-amperes reactive 34,40. On the VectorQ2 the reactive rating binds: 9 kilovolt-amperes reactive at 120 volts is 25 amperes per phase 34,40. The supplied current transformers carry a 200 ampere per phase rating, and larger feeds take custom transformers 40. Multiple units run in parallel with no master and no communication between units 40. The network analysis confirms the sharing before a second unit goes in.
On a 208Y/120 volt panel the correction range covers the 3rd, 9th, 15th and 21st of single-phase loads 40. R034B lists no rating above 480 volts, so a 4,160 volt chiller or compressor sits outside the product line 40. R034B lists no 400, 415 or 575 volt rating, so a 575 volt winder line is a custom application until a rating exists 40,51. R034B requires the neutral and ground connected, so a 480 volt delta, corner-grounded or ungrounded system sits outside the document 40.
The controller is an indoor IP20 unit rated for minus 5 to plus 42 degrees Celsius with no hazardous-location rating 40. A solvent room, a paint line or a classified area needs a rated enclosure outside the boundary 40. The controller is not compatible with residual-current or GFCI devices, which trip on milliamperes 40. A service ground-fault relay set in hundreds of amperes on a large 480Y/277 volt main is a different device 56. The service relay question comes to us with the plant’s one-line.
R034B states that correction begins immediately, and it also describes a three-minute diagnostic at power-on. So restart after a bus loss is unconfirmed 40. Until correction resumes the panel runs as installed, uncorrected. Size no feeder, transformer or breaker on the corrected current.
Path two, the future: active front ends, servos, solar, storage and the fab
The drives. Active front end drives draw 3 to 5% current distortion, and passive-filter drives reach 5% 13. Twelve-pulse fronts remove the 5th and 7th 1. Correction through the 23rd order covers a front end’s residual low orders within the 60 ampere budget 40. The switching-frequency sidebands stay with the drive’s own filter 37.
More axes move to servos and robots, each behind its own amplifier and DC bus 1. More of the process current then reaches the panel as rectifier current 1.
Solar, storage and the rules. Onsite solar and a battery behind the meter put an inverter on the plant bus. Into a fault, an inverter delivers about 1.1 to 1.5 times rated current, and a synchronous generator about six times for several cycles 60. Real power, reactive support and harmonic current for the loads on the same bus draw on one current budget 34.
A 2026 review of distribution blackstart singles out industrial demand: induction motors with tighter voltage tolerance and sizable starting currents 60. Cold load pickup forces inverters into current limiting 60. ERCOT’s NOGRR282 requires large computational loads to ride through disturbances since 2026-08-01, and FERC has ordered national standards by 2026-12-31 61. The rules bind data centers today, in the language a plant’s own drives and contactors have failed for decades 1,12,27.
The fab. SEMI F47 requires semiconductor processing, metrology and automated test equipment to continue operating through three sags 24. The points are 50% remaining voltage for 200 milliseconds, 70% for 0.5 seconds and 80% for 1.0 second 24. The mandatory table carries no point deeper than 50% 24.
The test applies one phase at a time, phase to neutral and phase to phase, and requires no three-phase sag 24. The specification has stood since 2006, and SEMI reapproved the text without technical change in 2012 24.
SEMI F42 is the superseded test method, and IEC 61000-4-11 and 61000-4-34 are the methods by input current 6,24. SEMI F49 guides a systems approach to power conditioning, and SEMI F50 frames the fab’s work with its utility on sags 24. In EPRI’s program, 70% of tools tested after F47 took effect met its points 23. Of the tools, 36% used a 3 to 5 kilovolt-ampere UPS scheme, and the typical solution hardware cost 5,000 dollars or less in 2002 23.
The topology follows. The utility feeds the substation, and the substation feeds the process power distribution 24. A UPS, a sag corrector or a dynamic voltage restorer feeds the tool power panels 23,24.
SDE’s place in the fab. The controller belongs on the facility-side motor control centers 42. A tool power panel takes a controller only where the site’s engineers accept a second fast converter after the maker’s application review 42. The controller is not a sag corrector, not a dynamic voltage restorer and not a UPS.
The controller does not meet SEMI F47 on a tool’s behalf and does not qualify a tool. SEMI F47 belongs to the tool 24.
On a fab substation the facility loads’ share of the bus voltage is hundredths of a percent, and the record is the larger contribution. The semiconductor example on this page stands on the standards and the published anchors alone.
The controller’s role on this path. While the source holds the controller’s band, the corrected loads’ reactive, harmonic and unbalanced current stays at the panel 40. The utility, the battery or the solar inverter carries the working current 60. The controller does not form the island, dispatch the sources, hold frequency, supply real power or store energy. Its fault current stops at its own current limit 40.
Why SDE is critical on both paths
Most power quality equipment reacts to a voltage symptom after it has formed, in seconds. A capacitor bank switches, a regulator settles and the current that made the symptom keeps flowing. Software-Defined Electricity starts from the current instead. It measures the full three-phase waveform at nanosecond resolution and corrects the current waveform digitally, at the load, in microseconds 40,41. The VectorQ controller samples the waveform 1,000 or more times per cycle 40.
The controller connects in parallel at the panel and sits outside the current path 42. It runs continuously, and removing or powering down the controller leaves the panel as installed 40. The effects below hold with the source inside the controller’s band 40.
The rule. V_panel = V_utility minus I × Z 1. The correction changes the second term, for the reactive, harmonic and unbalanced components of the corrected loads’ current, within 60 amperes per phase 40. The first term stays. On the illustrative panel the plant’s share of unbalance from an illustrative 20 amperes of negative sequence is 0.13% stiff and 1.1% weak 1. The correction removes each share for the corrected loads, within rating and down to the balancing residual 40. Four chains, one rule, one term.
Phase balance. Take a panel where a line-fed 100 horsepower motor is the largest load. The motor’s negative-sequence impedance sits near its locked-rotor impedance, 277 volts over 720 amperes, 0.385 ohms 16. Under a 2% utility unbalance, 5.5 volts of negative sequence, the motor draws negative-sequence current through the source impedance 1,2. The drop opposes the utility’s share at the motor’s terminals 1. On the 0.15 ohm source the terminal unbalance reads 1.44%, and on the 0.018 ohm source 1.91% 1. If the controller balances the source current, the correction supplies the motor’s negative-sequence current at the panel 40. The drop across the source vanishes, and the terminal unbalance returns to the full 2.0% on both sources 1,40. By the tip sheet’s rule an 80 degree motor runs 3.3 degrees hotter at 1.44%, 5.8 at 1.91 and 6.4 at 2.0 2. On the weak source, balancing the source current makes the motor 3 degrees hotter.
Two shares, opposite signs. The motor’s 14.4 amperes of negative sequence is 12% of its full-load current 16. R034B rates balancing within 20% of average, so we state first whether the controller acts on a 12% unbalance 40. Where the unbalance is load-driven, a single-phase welder on the same panel, the same correction removes the panel’s share and the motor runs cooler 1,40. The two shares carry opposite signs at a line-fed motor’s terminals. Only the network analysis with correction on and off separates them. Our assessment of two equipment racks on a 208Y/120 volt panel read the phase power spread falling from 40 to 50% to within 1.6% 44. In one pilot on a 208 volt panel the phase spread read 4.2 amperes uncorrected and 0.5 amperes corrected 62. Both records are load-driven unbalance on stiff sources.
The bill. Apparent power equals real power divided by power factor, S = P / PF 34. Take an illustrative 100 kilowatt load at 0.70 true power factor, a figure our survey read on one mechanical room panel 34,50. The load draws 143 kilovolt-amperes and 102 kilovolt-amperes reactive 34. Under Xcel Energy’s formula the 100 kilowatts bill as 129 kilowatts of demand 39. Under Georgia Power’s schedule, where the company elects to meter reactive demand, 69 kilovolt-amperes reactive sit above one third of the kilowatts 38. At 0.42 dollars each the excess bills 29 dollars in the month 38. The survey’s power factor includes the drives’ distortion, and a reactive meter bills displacement only, so the billed figures sit below the arithmetic 34,50. For the corrected panels, the service meter sees the working power and the controller’s own draw, and the uncorrected panels bill as before 40. We state no dollar saving without the tariff and the plant’s own meter data.
Cost of poor quality. The American Society for Quality (ASQ) defines cost of poor quality as the cost of providing poor quality products or services 53. Internal failure costs remedy defects found before delivery 53. A sag stop and a scrapped lot sit in the internal failure column of the plant’s own accounting 53. The correction changes one link of each chain, and we claim no scrap, yield, defect or downtime change from it. The plant’s own records, with correction on and off, are the only evidence for the rest of the chain.
Rating and heat. For the corrected loads, the transformer, the feeder and the generator carry working current 34. Conduction loss falls with the square of current 1. In the illustrative example the source current falls from 85 to 72 amperes per phase. The feeder’s conduction loss falls 28% for those loads, tens of watts on a short feeder. The controller’s own losses land on the same panel. They run under 150 watts typical and up to 3.6 kilowatts at full correction on a VectorQ5 40. The differences between the bench rows imply 263 to 342 watts 43. Inside the fence the net in this example is a loss. We claim no net heat saving without the site’s data. The motor’s heat stands on its own chain, and the correction reaches the motor only through the voltage at its terminals 2,17,18.
Speed. A motor start drops the voltage at once 1. A half cycle at 60 hertz is 8.3 milliseconds. The controller steps its correction in under 5 microseconds. It responds to a change in load current in under 100 microseconds: a weld burst, a press stroke or a drive shifting its harmonics 40,41. A transfer switch has one sixth of a second, a capacitor bank 1 to 3 seconds and a generator regulator seconds 1,41,49.
Protection, listing and interfaces. True-RMS sensing meters, relays and trip units read distorted current correctly 1. The feeder and main breakers upstream of the corrected panel see lower RMS current, with harmonics and reactive current removed. Branch breakers and motor overloads on the panel see the same current as before. The controller’s breaker and fault contribution enter the coordination study like any other panel device 40. R034B limits its touch current to 3.5 milliamperes AC, returned through the panel’s grounding system 40. We hold CE conformity assessment per IEC 62477-1, assessed to the 2012 edition with amendment 1 of 2016, and the current edition is 2022 40,57. Each installation carries a UL field evaluation 40. The controller runs with no internet dependency and no cloud latency 42. Its network interface enters the plant’s segmentation like any other panel device.
Observability. Class A power quality meters compute magnitudes over 10 or 12 cycles, about 200 milliseconds 35. The controller measures the current under correction and logs each correction at the panel 42. The panel record shows the current the machines drew through the event. The two shares appear where correction cycles on and off at comparable load.
The record. Our industrial record holds five items and two gaps. We have surveyed six panels on a 480Y/277 volt plant service, uncorrected, with a survey-grade instrument 50. The numbers on this page carry its caveats 50. Our bench test on a compressor at 460 volts read the row pairs above 43. We have proposed a plant pilot on the same method: a month of baseline logging, then a month of correction 51. Vibration and temperature sensors sit on the motor under test 51. The proposal stands unexecuted 51. Our assessment of two equipment racks measured the mechanism of neutral and unbalance correction on a 208Y/120 volt panel 44.
The trial and the gaps. The UK Ministry of Defence funded our bench trial, with Underwriters Laboratories as the independent third party 45. The bench carried a test motor, a brake motor, a drive and capacitors 45. Its results and caveats sit on Press and Case Studies 42,45. The two gaps: we hold no corrected measurement at a manufacturing plant, and no measurement of any kind at a semiconductor fab.
It sounds like one drive panel trips on dips the rest of the plant rides through. Nobody has separated the plant’s share from the utility’s. The missing piece is a record of which share tripped it.
We ship the VectorQ2 for 208 volt and the VectorQ5 for 480 volt networks, and both are in production 42. The network analysis sets controller count and rating 42.
The controller satisfies no reliability standard on its own, and no U.S. national laboratory has characterized the figures 47. Pilots start with an on-site electrical network analysis measured against the plant’s own baseline, with correction cycled on and off 42.
Start with a one-month log at one panel, with correction cycled on and off, before specifying a controller. Use the contact form. State the panel voltage and grounding, the drive, servo and starter types on the panel, and any UPS or sag corrector on the tool power. Name any capacitor bank, filter or ground-fault protection on the service. Bring the tariff sheet, the sag log and the worst machine’s stop history.
Four PQ Components pages explain the mechanisms behind this page. Harmonics is the drive current and the heat it makes in the transformer. Power Factor is the penalty and why a capacitor bank fixes only half of it. Electric Optimization is the arithmetic of the headroom the wasted current occupies. Standards Compliance names the window and the point IEEE 519 is measured at.
Sources
- U.S. Army. TM 5-689, ADP/Computer Electrical Installation and Inspection for Command, Control, Communications, Computer, Intelligence, Surveillance, and Reconnaissance (C4ISR) Facilities. Headquarters, Department of the Army, 2001-09-10. Paragraphs 3-1 (industrial control equipment, disturbances passing through internal power supplies, scrambled data looking like a hardware or software failure), 3-1 a(4) (every industrial facility on three-phase power, wye with ground or grounded and ungrounded delta, 480 and 208 volt three-phase and 277 and 120 volt single-phase loads), 3-2 b(1) (sags from switching on large motors, electric furnaces and air conditioning, inrush drops the voltage, regulation takes a definite period to recover), 3-2 b(2) (sags reflected through internal DC supplies, equipment re-initializing after a severe sag, equipment shutting down and staying down below a limit for more than a few milliseconds, part of an integrated system restarting and the balance not), 4-3 d (an industrial process controller with sensors and actuators located remotely), 4-6 b(7) (multiple grounding points at slightly different potentials, ground currents as noise causing errors in computation), 4-6 c(2) (a potential difference between the ends of a grounding conductor connecting two pieces of equipment, data errors), 5-1 (harmonic amplitude equals the fundamental divided by the order, 20 and 14.3 percent, practice lower because of system impedance), 5-2 and 5-2 a (harmonic sources in utility or industrial systems: rectifiers, DC motor drives, adjustable frequency AC drives, UPS, arc furnaces, static motor starters, n = kp ± 1, six-pulse and twelve-pulse orders), 5-2 c and 5-3 c(3) (numerical controlled machines as harmonic sources and as equipment sensitive to power line pollution, responding incorrectly to normal inputs, giving false signals or not responding), 5-3 c(1) (power factor capacitors applied to converters and the problems which followed), 5-4 a(2) and b (source inductance resonating with the power factor capacitor bank, harmonics amplified and not source limited, fuse operation, capacitor failure, relay tripping, overheating), 5-5 a (motors as linear loads), 5-5 b(4) and (5) (AC speed controls rectify to DC and invert back to adjustable-frequency AC, power supplies for programmable controllers convert AC to low-voltage DC through high-speed switching), 5-6 c and d (triplen currents adding in the neutral, 1.73 to 3.0 times), 5-7 a to d (hysteresis, eddy current and skin effect, transformers and generators under 70 percent shut down on over-temperature, motors on distorted voltage draw harmonic current and overheat unless derated, motors particularly affected by the fifth harmonic), 5-8 a to c (zero crossings, hunting, load sharing), 5-9 a (E = I × Z, distortion lower on a low-impedance source and higher on a high-impedance source), 5-11 b(3) in the 2001 numbering (tuned filter selected for one load and one source impedance, changing the load, the source or the location degrades performance), 5-12 a(2) and f in the 2001 numbering (average-sensing meters read pulsed current as much as 50 percent low, older average-sensing relays fail to trip on overcurrent or trip unnecessarily), 5-13 d in the 2001 numbering (true-RMS sensing meters, relays and trip units), 6-4 f (5 to 100 times sub-transient reactance, nonlinear loads react entirely differently on a generator), 6-4 h and i (harmonic currents add kVARs, stator core and rotor pole face heating), 6-4 n (capacitor resonance caution on a generator), 6-6 e (transfer switch operating time not to exceed one sixth of a second), 6-6 f(1)(b) (stalled rotor about six times running current, ten times as a controller design ratio, in-phase monitors), 6-6 j(1) (25 to 35 percent more inrush and 156 to 183 percent stresses out of phase) and 6-6 p (adjustable frequency drives reading an interruption as low voltage, SCRs turned fully on, severe inrush blowing fuses or damaging the SCRs, high-speed sensing shutting the drive down and restarting through a soft current limit). The WBDG URL serves the 2001 edition. The 2006 edition (28 April 2006, project file) renumbers chapter 5 from paragraph 5-10 onward by one and adds at 5-4 b the resonance order h = square root of short-circuit MVA divided by capacitor Mvar, citing IEEE 519-1992. The resonance order in the body is cited to the 2006 passage. https://www.wbdg.org/FFC/ARMYCOE/COETM/tm_5_689.pdf
- U.S. Department of Energy, Advanced Manufacturing Office. Motor Systems Tip Sheet 7, Eliminate Voltage Unbalance, DOE/GO-102012-3733, 2012-11 (percent voltage unbalance defined as 100 times the largest deviation from the average divided by the average, unbalances above 1 percent require derating per NEMA MG 1 Figure 20-2, six causes of unbalance, a 100 horsepower motor at 2.5 percent unbalance running 27.7 percent current unbalance with efficiency 94.4 to 93.0 percent, current unbalance 6 to 10 times the voltage unbalance, total temperature rise equals the balanced rise times 1 + 2 × (percent unbalance)² / 100, an 80 degree Celsius rise motor running 6.4 degrees hotter at 2 percent, winding insulation life halved for each 10 degree Celsius increase). https://www.energy.gov/sites/prod/files/2014/04/f15/eliminate_voltage_unbalanced_motor_systemts7.pdf
- NEMA. ANSI/NEMA MG 1, Motors and Generators. Current edition MG 1-2024, paywalled. Free NEMA excerpt of MG 1-2016 Revised 2018, Part 12: clause 12.44.2 (torque at any speed approximately proportional to the square of the voltage) and clause 12.45 (polyphase motors operate successfully at rated load when voltage unbalance at the terminals does not exceed 1 percent). The 5 percent not-recommended limit as reproduced in a leading drive maker’s note Three-Phase Voltage Imbalances, LVD-EOTKN113U-EN. Derating curve values not asserted. https://www.nema.org/docs/default-source/standards-document-library/mg-1-part-12-watermark.pdf and https://library.e.abb.com/public/772bbffb5d6f41ffb88fc5d9da927dfd/LVD-EOTKN113U-EN_Three_Phase_Voltage_Imbalance_A.pdf
- ANSI C84.1-2020 (R2025), American National Standard for Electric Power Systems and Equipment, Voltage Ratings (60 Hertz). Reaffirmed 2025. Paywalled. Range A service voltage at 480Y/277 volts, 456 to 504 volts, as reproduced by Pacific Power, Voltage Level and Range 1C.2.1, 2024-11-26. The 3 percent unbalance recommendation as reproduced by PG&E, Understanding Electric Power Characteristics, 2018-07. https://www.pacificpower.net/content/dam/pcorp/documents/en/pp-rmp/power-quality-standards/1C_2_1_PF.pdf and https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/Understanding_Electric_Power.pdf
- IEEE Std 519-2022, IEEE Standard for Harmonic Control in Electric Power Systems. Table 1 (voltage distortion limits for buses of 1 kilovolt and below: 5.0 percent individual, 8.0 percent total) and Table 2 (current distortion limits for 120 volt through 69 kilovolt systems, total demand distortion 5.0 to 20.0 percent by short-circuit ratio, referenced to the maximum demand current). Active. Standard text paywalled. Values as reproduced by Power Quality Blog, 2023-06-01, and a harmonic filter maker’s summary. https://standards.ieee.org/ieee/519/10677/ and https://powerquality.blog/2023/06/01/power-quality-ieee-519-2022/
- IEC 61000-4-11:2020, Electromagnetic compatibility (EMC), Part 4-11: Testing and measurement techniques, Voltage dips, short interruptions and voltage variations immunity tests for equipment with input current up to 16 A per phase, edition 3.0, 2020-01-28. Table 1, Class 3 test levels (0 percent for half a cycle and one cycle, 40 percent for 10 or 12 cycles, 70 percent for 25 or 30 cycles, 80 percent for 250 or 300 cycles). Paywalled, values as reproduced in the standard’s public preview. Equipment above 16 amperes per phase falls under IEC 61000-4-34:2005 with amendments 1 (2009) and 2 (2025-08-07), levels not asserted. https://cdn.standards.iteh.ai/samples/102366/465c32780e9d4ca0bf9edd5844e3c166/IEC-61000-4-11-2020.pdf and https://webstore.iec.ch/en/publication/109082
- IEEE Std 1668-2017, IEEE Recommended Practice for Voltage Sag and Short Interruption Ride-Through Testing for End-Use Electrical Equipment Rated Less than 1000 V. Active, replaced the 2014 trial-use version, revision project P1668 approved 2024-09-26. Paywalled. Test points of 50 percent for 0.2 seconds, 70 percent for 0.5 seconds and 80 percent for 2.0 seconds per a vendor summary. https://standards.ieee.org/ieee/1668/11792/ and https://www.elspec-ltd.com/using-ieee-1668-for-power-quality-study/
- Information Technology Industry Council, Technical Committee 3. ITI (CBEMA) Curve Application Note, revised 2000. Scope: 120 volt nominal computer equipment from 120, 208Y/120 and 120/240 volt systems. Sections 3.5 (sags to 80 percent for 10 seconds, 70 percent for 0.5 seconds) and 3.6 (dropout up to 20 milliseconds). https://www.itic.org/resources/Oct2000Curve-UPDATED.doc
- A leading drive maker’s design guide, MG38C222, 2018-01, section 5.2.5 Mains dropout (the drive keeps running until the DC-link voltage drops below the minimum stop level, typically 15 percent below the lowest rated supply voltage), and the same drive series’ programming manual, parameter 14-01 Switching Frequency (1.0 to 16.0 kilohertz). The 436 volt DC, 518, 454 and 324 volt figures in the body are our arithmetic on the guide’s statement at 1.35 times the line voltage. https://docs.galco.com/techdoc/dnfs/driv_ac_fc302_dg.pdf and https://www.manualslib.com/manual/1636874/Danfoss-Vlt-Automationdrive-Fc-302.html?page=192
- A leading drive maker’s standard control program firmware manual, 3AXD50000016097 Rev H, 2022-02-28, Undervoltage control (power loss ride-through): the drive rides through short power losses on the kinetic energy of the rotating motor, and the ride-through time depends on the load torque and the load inertia. https://library.e.abb.com/public/052c19b4002f45cf908d536363a39bb4/ASCD2216x_en.pdf
- A leading drive maker’s technical manual, SIEP C710616 27C, parameter L2-01 Momentary Power Loss Operation Selection, setting 0 disabled: if power is not restored within 15 milliseconds, a Uv1 fault results and the drive stops the motor. https://www.manualslib.com/manual/346442/Yaskawa-A1000-Series.html?page=249
- Pacific Gas and Electric. Power Quality: Voltage Sag Ride-through Mitigation in Sequence by Increasing Cost, 2018-07 (adjustable speed drives with automatic restart typically wait 30 to 60 seconds for the circuit to stabilize, page 3, NEMA AC contactor ride-through to 85 percent and DC contactor to 80 percent, page 4). https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/Voltage_Sag_Ridethrough_Mitigation.pdf
- A leading drive maker’s comparison, Active front end drive versus passive filter, comparison of harmonic mitigation technology, LVD-EOTKN073U-EN Rev A, 2021-09-30 (six-pulse drive with no internal impedance about 80 percent current distortion measured at the lugs, as high as 120 percent, AC line reactor or DC choke 35 to 50 percent, passive filter drive 5 percent, active front end 3 to 5 percent). Manufacturer typical values. https://library.e.abb.com/public/5eb87f704cc14fa596fb610f5dfb27a3/LVD-EOTKN073U-EN%20_REVA.pdf
- A leading drive maker’s guide, Harmonics: A Guide to Supply Harmonics and Other Low-Frequency Disturbances, issue 2020-09, section 5 (only odd harmonics of the order n = kp ± 1). https://www.nidec-netherlands.nl/media/2926-engineering-documentatie-a-guide-to-supply-harmonics-andother-low-frequency-disturbances-iss6-0704-0002.pdf
- A leading maker’s softstarter handbook, 1SFC132060M0201, 2010-11 (direct on line start usually 6 to 8 times rated current, page 13, softstarter about 3 to 4 times rated current during the start, page 32, torque reduced with the square of the voltage, page 14, 50 percent voltage giving about 25 percent torque, page 23). https://library.e.abb.com/public/6b4e1a3530814df0c12579bb0030e58b/1SFC132060M0201.pdf
- NEMA. Motor Terminology and Electrical Performance Characteristics, NEMA Motor and Generator Guides library, undated (locked rotor current typically 600 to 700 percent of full load). The 0.385 ohm negative-sequence impedance in the body is our arithmetic, 277 volts over 720 amperes. https://www.nema.org/docs/default-source/motor-and-generator-guides-and-resources-library/6-electric-motor-terminology-and-performance-characteristics-v2.pdf?sfvrsn=62ad61a9_2
- Muñoz Tabora, J., de Lima Tostes, M. E., Ortiz de Matos, E., Mota Soares, T. and Bezerra, U. H. Voltage Harmonic Impacts on Electric Motors: A Comparison between IE2, IE3 and IE4 Induction Motor Classes. Energies 13(13), 3333 (2020). Introduction (temperature rise of induction motors due to harmonics approximately 4 to 6 degrees Celsius, a literature value). Open access. https://doi.org/10.3390/en13133333
- Zhang, J., Wang, J., Li, H., Zhang, Q., He, X., Meng, C., Huang, X., Fang, Y. and Wu, J. A Review of Reliability Assessment and Lifetime Prediction Methods for Electrical Machine Insulation Under Thermal Aging. Energies 18(3), 576 (2025). Introduction (a 10 degree Celsius rise corresponds to a 50 percent reduction in insulation lifetime). Open access. https://doi.org/10.3390/en18030576
- Gnacinski, P., Peplinski, M., Muc, A. and Hallmann, D. Induction Motors Under Voltage Unbalance Combined with Voltage Subharmonics. Energies 17(24), 6324 (2024). Section 3.1 (at 2 percent voltage unbalance the pulsating torque component at 100 hertz reaches 15.7 percent of rated torque, measured with a 0.3 percent subharmonic present) and section 3.2 (maximal vibration velocity 1.580 millimeters per second for voltage unbalance alone, 2.212 with subharmonics added). A 50 hertz line-fed test motor. Open access. https://doi.org/10.3390/en17246324
- Motoki, E. M., de Carvalho Filho, J. M., da Silveira, P. M., Pereira, N. B. and de Souza, P. V. G. Cost of Industrial Process Shutdowns Due to Voltage Sag and Short Interruption. Energies 14(10), 2874 (2021). Questionnaire survey of 33 facilities in twelve industrial sectors in Brazil, 55.9 percent response rate (average cost per event US $7,364.75, average cost per interrupted demand US $6.72 per kilowatt, Table 5 by sector: automotive US $6,000 to $13,048, plastics US $1,640 to $9,667, textiles about US $1,500). Self-reported costs, dollar year not stated in the text. Open access. https://doi.org/10.3390/en14102874
- Sullivan, M. J., Schellenberg, J. and Blundell, M. Updated Value of Service Reliability Estimates for Electric Utility Customers in the United States. LBNL-6941E, Lawrence Berkeley National Laboratory, 2015-01. Table ES-1, medium and large commercial and industrial customers over 50,000 kilowatt-hours a year, cost per event in 2013 dollars: momentary 12,952, 30 minutes 15,241, 1 hour 17,804, 4 hours 39,458, 8 hours 84,083, 16 hours 165,482. Survey-based two-part model on 34 datasets from 10 utilities, 1989 to 2012, over 105,000 observations. Momentary means an interruption, not a sag. https://www.osti.gov/servlets/purl/1172643
- Larsen, P. H. et al. ICE Calculator 2.0 Phase 1 Final Report. Lawrence Berkeley National Laboratory, 2025-05. Table 4.6, non-residential cost per event in 2023 dollars: momentary 609, 2 hours 2,839, 8 hours 6,172, 24 hours 12,646, from 3,874 validated non-residential responses with a single distribution for all non-residential customers. https://eta-publications.lbl.gov/sites/default/files/2025-06/ice_2.0_phase_i_final_report_29may2025.pdf
- Stephens, M. Semiconductor Equipment Voltage Sag Immunity Improvements. EPRI PEAC Corporation, 2002-06-13, as reproduced by Power Quality Blog, 2021-12-02 (33 semiconductor tools tested plus subsystems, over 51 tools and 14 subsystems by 2002-04, audits of over 131 installed tools, emergency-off circuits causing shutdown in 47 percent of the tests, sags as minor as 78 percent of nominal lasting less than one cycle shutting down tools with sensitive relays, 70 percent of tools tested compliant after F47, 36 percent of tools using a 3 to 5 kilovolt-ampere UPS scheme, typical solution hardware 5,000 dollars or less). An EPRI technical paper, not a journal article, flagged by year. https://powerquality.blog/2021/12/02/technical-paper-semiconductor-equipment-voltage-sag-immunity-improvements/
- SEMI F47-0706 (Reapproved 0812), Specification for Semiconductor Processing Equipment Voltage Sag Immunity. Current, reapproved 2012-12 with no technical change, text paywalled. Envelope points as reproduced by a power supply maker’s application note (Table 1) and PG&E, Power Quality Bulletin Issue 3, 2018-07 (50 percent for 200 milliseconds, 70 percent for 0.5 seconds, 80 percent for 1.0 second, required of semiconductor processing, metrology and automated test equipment). Test vectors per SEMI’s 2006 overview (phase-to-neutral and phase-to-phase sags one phase at a time, three-phase sags not required, IEC 61000-4-11 methods at 16 amperes per phase or less and IEC 61000-4-34 above). SEMI F42-0600, test method, superseded by F47-0706. SEMI F49-0200 (Reapproved 1021), Guide for Semiconductor Factory Systems Voltage Sag Immunity, a systems approach to power conditioning, current. SEMI F50-0200 (Reapproved 1021), Guide for Electric Utility Voltage Sag Performance for Semiconductor Factories, current. The 200 volt scope threshold is not asserted. https://store-us.semi.org/products/f04700-semi-f47-specification-for-semiconductor-processing-equipment-voltage-sag-immunity and https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/Power_Quality_Bulletin_Issue3.pdf and https://dom.semi.org/web/wstandards.nsf/19A2E6E9C088D3958825733100743B15/$file/4OverviewofSEMIF47-0706.pdf
- A leading semiconductor maker’s PFC converter design guide, application note, Rev 1.1, 2016-02-22, section 2.5, equation 30 (output capacitance C at or above 2 P t_hold / (V² minus V_min²), rearranged to t_hold = C (V² minus V_min²) / (2 P)), and a second semiconductor maker’s technical note TN0024, Power supply hold-up time, 2007-02, equation 5 (E = ½ C V²). The 862 joule, 17 millisecond and 87,000 microfarad figures in the body are our arithmetic on the identity at 648 and 436 volts DC. The half-cycle to two-and-a-half-cycle range, the 3,750 and 18,000 microfarad cases and the 8.6 and 41 millisecond marks in Figure 2 are our arithmetic on the same identity. https://www.infineon.com/assets/row/public/documents/24/42/infineon-applicationnote-pfcccmboostconverterdesignguide-applicationnotes-en.pdf and https://www.st.com/resource/en/technical_note/tn0024-power-supply-holdup-time-stmicroelectronics.pdf
- Chiranga, F. and Masisi, L. Variable Speed Drive DC-Bus Voltage Dip Proofing. Energies 14(24), 8257 (2021). Section 1 (typical DC bus capacitance 75 to 360 microfarads per kilowatt) and section 6.2, Figure 13 (the drive tripped once the DC-link voltage dropped below the low trip setting of 288 volts on a 0.2 second short-term power interruption). A 400 volt class test drive. Open access. https://doi.org/10.3390/en14248257
- Pacific Gas and Electric. Power Quality: Variable Frequency Drives, Voltage Sag Impact and Mitigation, 2018-07, page 2 (drives typically programmed by the manufacturer to trip without delay, in some cases for a sag of only 90 percent of nominal) and page 3 (ride-through from a couple of milliseconds to 10 milliseconds for smaller drives under full load). https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/VFDSag_Impact_Mitigation.pdf
- Pacific Gas and Electric. Power Quality note on short duration voltage sags and disruptions, 2018-07, page 2 (an urban customer on average sees 1 or 2 interruptions a year and over 20 sags a year). https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/Short_Duration_Voltage_Sags.pdf
- Polat, O., Sezgin, M. S., Yumak, K. and Gul, O. Assessment of voltage sag events based on measurement studies in an industrial facility. 2018 18th International Conference on Harmonics and Quality of Power (ICHQP), 2018 (140 short-term voltage variation events recorded, 72 classified as sags, 36 of 72 sags between 10 and 100 milliseconds, none longer than one second, Table I counts by depth and duration). One industrial facility in Turkey, a textile plant, 11 days of measurement in 2017-08, conference paper, not open access, author copy consulted. https://www.academia.edu/119723891/Assessment_of_voltage_sag_events_based_on_measurement_studies_in_an_industrial_facility
- Turzynski, M. and Musznicki, P. A Review of Reduction Methods of Impact of Common-Mode Voltage on Electric Drives. Energies 14(13), 4003 (2021). Section 2 (common-mode voltage of plus or minus one sixth of the DC voltage for active states and plus or minus one half for the zero vectors) and section 4 (common-mode voltage derivative exceeding 5 kilovolts per microsecond without countermeasures regardless of cable length, Table 2). Open access. https://doi.org/10.3390/en14134003
- Pacific Gas and Electric. Power Quality: Solution of EMI Problems from Operation of Variable-Frequency Drives, 2018-07, page 1 (common-mode noise currents affecting control signals, encoder feedback, communication links for programmable logic controllers including RS-232, RS-485 and remote I/O, and ultrasonic, bar code and vision, weight and temperature sensors). https://www.pge.com/assets/pge/docs/contact-us/report-an-issue/VFD-EMI_problems.pdf
- IEEE Std 1100-2005, IEEE Recommended Practice for Powering and Grounding Electronic Equipment (ground loops and high-frequency noise disrupting logic and communication, as summarized in the EC&M overview of 1996-02-01). Inactive-Reserved since 2021-03-25. Cited as a historical record, not as a current standard, table values not asserted. https://standards.ieee.org/ieee/1100/3055/ and https://www.ecmweb.com/content/article/20887203/an-overview-of-ieee-1100-the-emerald-book
- NXP Semiconductors N.V. Press release filed as Exhibit 99.1 to Form 8-K, 2021-03-11 (the storm and loss of utilities caused a full shutdown of two Austin wafer fabs beginning 2021-02-15, utilities restored 2021-02-27, approximately one month of wafer production lost, expected impact of approximately 100 million dollars of second-quarter revenue). Kioxia Corporation, Notice Regarding Production Status of Yokkaichi Operations, 2019-06-28 (an unexpected power outage in the Yokkaichi region on 2019-06-15, the vast majority of production equipment operational by mid-July, no loss figure). Both are outage records, not sag records. https://www.sec.gov/Archives/edgar/data/1413447/000141344721000021/nxpaustinproductionupdate2.htm and https://www.kioxia.com/en-jp/about/news/2019/20190628-1.html
- IEEE Std 1459-2025, IEEE Standard Definitions for the Measurement of Electric Power Quantities Under Sinusoidal, Nonsinusoidal, Balanced, or Unbalanced Conditions (apparent, active and reactive power, displacement and total power factor under distortion, RMS current squared equals fundamental current squared plus harmonic current squared, fundamental active and reactive components in quadrature). Published 2025-05-16, supersedes IEEE Std 1459-2010. The 85, 72 and 45 ampere figures in the body are arithmetic on S = P / PF at 480 volts. https://standards.ieee.org/ieee/1459/7578/
- IEC 61000-4-30:2025, Electromagnetic compatibility (EMC), Part 4-30: Testing and measurement techniques, Power quality measurement methods, edition 4.0, 2025-10-24 (class A basic measurement interval of 10 cycles at 50 hertz or 12 cycles at 60 hertz, dip and swell detection on half-cycle RMS, class S retained). https://webstore.iec.ch/en/publication/71611
- IEEE Std 1453-2022, IEEE Standard for Measurement and Limits of Voltage Fluctuations and Associated Light Flicker on AC Power Systems, published 2023-02-27, superseding IEEE 1453-2015, and IEC 61000-4-15:2010, Flickermeter, functional and design specifications, edition 2.0. Both paywalled. The Pst compatibility level of 1.0 on low and medium voltage as reproduced by Pacific Power, Voltage Fluctuation and Flicker 1C.5.1, 2024-11-26, Table 1. https://standards.ieee.org/ieee/1453/10459/ and https://www.pacificpower.net/content/dam/pcorp/documents/en/pp-rmp/power-quality-standards/1C_5_1_PF.pdf
- IEC 61800-3:2022, Adjustable speed electrical power drive systems, Part 3: EMC requirements and specific test methods for PDS and machine tools, edition 4.0, 2022-11-30. Paywalled. Cited for existence and scope, category limits not asserted. https://webstore.iec.ch/en/publication/65056
- Georgia Power Company. Electric Service Tariff, Power and Light Medium, Schedule PLM-18, effective with bills rendered for the billing month of 2025-01 (where there is an indication of a power factor of less than 95 percent lagging the Company at its option installs metering to measure reactive demand, excess reactive demand is kVAR in excess of one third of the measured actual kW, billed at 0.42 dollars per excess kVAR). https://www.georgiapower.com/content/dam/georgia-power/pdfs/business-pdfs/tariffs/2025/plm-18.pdf
- Northern States Power Company, Minnesota (Xcel Energy). Minnesota Electric Rate Book, Section 5, General Service, Sheet 5-27, effective 2017-10-01 (adjusted demand for billing determined by dividing the maximum actual demand in kW by the power factor but not more than 90 percent and multiplying by 90 percent, power factor metered for three-phase services above 200 amperes or above 480 volts). https://www.xcelenergy.com/staticfiles/xe/Regulatory/Regulatory%20PDFs/rates/MN/Me_Section_5.pdf
- 3DFS. VectorQ Technical Overview, Installation and Application Notes, revision R034B (VectorQ2 208 volt, three-phase with neutral, up to 60 kW, 9 kVAR, 50 A per phase. VectorQ5 480 volt, three-phase with neutral, up to 120 kW, 60 kVAR, 60 A per phase. No rating above 480 volts, custom voltages on request. Neutral and ground must be connected. Voltage tolerance plus or minus 15 percent, frequency tolerance plus or minus 0.5 percent. Sensing under 10 nanoseconds, correction under 5 microseconds. Harmonic measurement to the 53rd order and correction to the 23rd. Neutral current reduced to near zero by active phase balancing, phase load balancing within 20 percent of average. 1,000 or more samples per sine wave. Heat dissipation under 2.4 kW and under 3.6 kW at full load. Connection by a three-line, neutral and ground cable in parallel to the network through a dedicated breaker, current transformers on the incoming phase conductors rated to 200 A per phase with custom ratings on request. Installation step 4 specifies a 50 A breaker. Multiple units in parallel with no master and no inter-unit communication, each unit measuring and correcting the conditions at its own connection point. A unit corrects to its rated output and the remainder passes uncorrected. Overload behavior current-limited. Correction stated to begin immediately, and a diagnostic of about three minutes at power-on. A second capacitor bank or active filter on an existing installation requires re-engineering the coordination. Not compatible with RCD or GFCI devices. Touch current 3.5 mA AC. CE conformity assessment per IEC 62477-1:2012 plus A1:2016, UL compliance by field evaluation. Indoor, IP20, minus 5 to plus 42 degrees Celsius, 85 percent humidity, 1,000 m altitude, EMC Class A, no hazardous-location rating stated. The electrical system continues to operate as before if the controller is removed or powered down. Behavior outside the voltage and frequency band not stated). Product document. First-party.
- 3DFS. SDE Technical Training Document, version 2.0 (response-time comparison: SDE under 100 microseconds, active harmonic filter 1 to 10 milliseconds, capacitor banks 1 to 3 seconds, automatic voltage regulator 1 to 10 seconds. Correction current equals the negative of the harmonic, reactive and imbalance components). Internal document. First-party.
- 3DFS. Products page (VectorQ2 and VectorQ5 in production, parallel connection at the panel, outside the current path, installation without interrupting the circuit, each controller measures the current under correction, live record of power quality at the panel, pilot starts with an on-site network analysis with the controller cycling on and off against the facility’s baseline), SDE Summary page (the controller logs each correction), Resilience page (no internet dependency and no cloud latency), Data Centers and Compute page (a controller on a UPS output as a second fast converter under the UPS maker’s application review) and Press and Case Studies page (the trial results and caveats). 3DFS website. First-party. /products, /technology/sde-summary, /technology/resilience, /solutions/data-centers-compute and /press-proof
- 3DFS. SDE Power Quality Correction Test Results, compressor load, analyzer data sheet, Test 4 rows 4e_0 and 4e_1 (motor load on 460 volts, 60 hertz, VectorQ5 in parallel on the 480 volt panel, analyzer at the panel with the controller inside the measurement. Correction off: 6,992 W, 4,852 var, 8,511 VA, power factor 0.82, average current 9.93 A, average current distortion 4.96 percent. Correction on: 7,066 W, 488 var, 7,083 VA, power factor 1.00, average current 8.25 A, current distortion 4.21 percent. Row 4d_0 to 4d_1: 6,800 to 7,214 W, 4,827 to 471 var. Row 4e_3, controller powered off with the load running: 6,724 W, 5,659 var, power factor 0.77, average current 10.25 A, average current distortion 3.27 percent. The differences between rows imply a controller draw of 263 to 342 W. Voltage distortion 1.36 to 1.39 percent in every row). Unpublished bench test. First-party.
- 3DFS. Electrical Network Analysis, equipment racks, redacted report, summary values (VectorQ2a in parallel on two equipment racks fed from a UPS through a distribution panel at about 120 volts per phase. Rack 1 current distortion 6.4 to 1.9 percent, power factor 0.931 to 0.999, phase power spread minus 1.00, minus 39.06 and plus 40.06 percent to plus 1.35, minus 0.93 and minus 0.42 percent. Rack 2 current distortion 13.2 to 3.6 percent, phase spread plus 38.65, plus 11.20 and minus 49.85 percent to minus 0.64, plus 1.52 and minus 0.88 percent. Corrected active power at the connection 57 and 70 watts above uncorrected). Redacted site assessment. First-party. Cited on this page for the mechanism of unbalance correction on a 208Y/120 volt panel only.
- UK Ministry of Defence. Sanctuary Awards 2020, Highly Commended, Energy, Low Carbon and Resource Efficiency: The Defence Innovation Software Defined Electricity Project, published 2021-03-16 (trials in 2020-02 at the 3DFS facility in North Carolina, funded by the Defence Innovation Unit, with Underwriters Laboratories as independent third party. The entry states the technology had not been industrially deployed at any scale and names the MOD as the only external organisation to have tested the technology). GOV.UK. Bench setup from the trial summary: a 1.5 horsepower three-phase test motor, a 3 horsepower brake motor, a 3.7 kilowatt drive, capacitors, a heater and a single-phase motor on a 208 volt panel. Existence and setup only. https://www.gov.uk/government/publications/mods-sanctuary-awards-winners-2020/full-list-of-the-sanctuary-award-winners-2020
- Army Technology, 2021-04-01, reprint of the Brite Innovation Review interview with Lt Cdr Jonathan Parker, UK MOD Defence Innovation Unit (correcting at the last load does not propagate back up the network). https://www.army-technology.com/features/current-challenges-how-ai-enabled-power-distribution-could-prevent-losses/
- 3DFS. The Capacity Already in the Wires: Grid Reliability in the Fast Timescales, Technical Companion, version 2.0, section 8 (SDE is not a UPS and not a generator, satisfies no reliability standard on its own, and no U.S. national laboratory has characterized the figures). First-party. Listed on the Press and Case Studies page.
- IEEE Std 3002.7-2018, IEEE Recommended Practice for Conducting Motor-Starting Studies and Analysis of Industrial and Commercial Power Systems, and IEEE Std 3002.8-2018, IEEE Recommended Practice for Conducting Harmonic Studies and Analysis of Industrial and Commercial Power Systems. Active. Paywalled. Cited for the existence of the study practice. https://webstore.ansi.org/standards/ieee/IEEE30022018-1735280 and https://webstore.ansi.org/standards/IEEE/ieee30022018
- ISO 8528-5:2025, Reciprocating internal combustion engine driven alternating current generating sets, Part 5: Generating sets, edition 6, 2025-05, superseding the 2022 edition. Class G2 values of minus 10 percent transient frequency deviation and minus 20 percent transient voltage deviation on a load increase, with 5 and 6 second recovery, as reproduced from the 2018 edition’s table in a leading generator maker’s Bulletin 5544421, Transient Performance of Generating Sets, 2019-03. https://www.iso.org/standard/85960.html and https://mart.cummins.com/imagelibrary/data/assetfiles/0058629.pdf
- 3DFS. Power Quality Analysis Report, industrial plant (480Y/277 volt service, six panels, unfiltered recordings with an IEC 61000-4-30 Class S equivalent instrument, no controller installed. First drive panel: current distortion 52.0 percent, 5th 27.4, 7th 14.3, 11th 4.9, 23rd 3.3 percent. Second drive panel: 21.6 percent, 5th 8.4 percent. Mechanical room pump panel: 21.4 percent, K-factor 23.0, true power factor 0.696. HVAC and lighting panels: 5.0 and 14.8 percent. Average voltage distortion 3.5 percent as stated. Voltage unbalance 0.16 to 0.31 percent by panel, one panel reading zero, current unbalance 10.7 percent on an HVAC and lighting panel and 11.2 percent on a second utilities panel, 7.0 percent on the second HVAC and lighting panel. Report caveats: screening assessment, THD-I not TDD, short recordings advisory, single measurement session). Customer, industry, site, date and utility withheld. The report’s dollar figures, PQR scores and projected corrected values are not used. First-party survey.
- 3DFS. Pilot proposal, industrial plant (one-line: line transformer, a long feeder run to an entry panel, a further run to a switch room, then runs to 575 volt and 480 volt machine drives and to a process site with circulation pump drives. Method: at least one month of baseline logging, one month of correction at the same points with logging continued, vibration and temperature sensors on the motor under test, installation in parallel without interrupting service. Plan C names a 575 volt controller, for which R034B carries no rating). Customer, industry, site and date withheld. Proposal, not a record of results. First-party.
- Zielinski, D., Stefanczak, B. and Jedrys, K. Phase-Independent Reactive Power Compensation Based on Four-Wire Power Converter in the Presence of Angular Asymmetry between Voltage Vectors. Energies 15(2), 497 (2022). Voltage asymmetry and phase-angle shift from single-phase and converter loads growing worse where short-circuit impedance is high, per-phase reactive compensation. Open access. https://doi.org/10.3390/en15020497
- American Society for Quality. Cost of Quality (COQ), quality resources page (cost of poor quality defined as the costs associated with providing poor quality products or services, internal failure costs incurred to remedy defects discovered before the product or service is delivered to the customer). https://asq.org/quality-resources/cost-of-quality
- Application bulletin on harmonics in electrical systems, page 2 (three-phase nonlinear loads widespread in factories and industrial plants, effects list: overheating of distribution equipment, high voltages and circulating currents from resonance, equipment malfunctions from excessive voltage distortion, increased internal losses and shortened life, false tripping of branch circuit breakers, metering errors, fires, generator failures, communication errors) and pages 5 and 6 (K-factor table: K-4 under 35 percent, K-7 under 50 percent, K-13 under 75 percent, K-20 under 100 percent harmonic-producing load). Project file HarmonicsInYourElecSystem.pdf.
- IEEE Std C57.110-2018, IEEE Recommended Practice for Establishing Liquid Immersed and Dry-Type Power and Distribution Transformer Capability when Supplying Nonsinusoidal Load Currents (winding eddy-current loss proportional to the square of harmonic order). Active. The K-factor K = Σ I_h(pu)² × h² as reproduced in a leading maker’s K-factor technical paper 1TQC194900E0001, 2023. https://standards.ieee.org/ieee/C57.110/5948/
- NFPA 70, National Electrical Code, 2026 edition. Paywalled. Cited for the existence of Article 430 (motors, motor circuits and controllers) and of section 230.95 (ground-fault protection of equipment on solidly grounded wye services of more than 150 volts to ground and 1,000 amperes or more). Settings and thresholds not asserted. https://webstore.ansi.org/standards/nfpa/nfpa702026
- IEC 62477-1:2022, Safety requirements for power electronic converter systems and equipment, Part 1: General, edition 2.0, 2022-05-20, replacing IEC 62477-1:2012 plus A1:2016. https://webstore.iec.ch/en/publication/28936
- Arenas Sarmiento, J. J., Herazo Acevedo, J. H., Sousa Santos, V., Silva Ortega, J. I. and Candelo-Becerra, J. E. Energy evaluation of pumping systems in a clean water plant: A study case. Journal of Sustainable Development of Energy, Water and Environment Systems 11(4), 1110466 (2023). Power quality section (predominance of the fifth, seventh and eleventh orders from six-pulse drives, current distortion 11.09 percent at the common connection point). The plant pumps cooling water at an industrial site in Colombia. Open access. https://doi.org/10.13044/j.sdewes.d11.0466
- Zhang, Y., Wang, Y. and You, X. Tolerance of Electromagnetic Relay to Voltage Sags and Short Interruptions. Frontiers in Energy Research 9, 766472 (2021) (magnitude tolerance of electromagnetic relays 48 to 74 percent of nominal, duration tolerance 5 to 28 milliseconds). Open access. https://doi.org/10.3389/fenrg.2021.766472
- Shi, W., Bai, C. and Wang, Z. Power distribution system blackstart restoration using renewable energy. Nature Communications 17, 8498 (2026). Industrial demand with induction motors of tighter voltage tolerance and sizable starting currents, cold load pickup as a brief inrush with substantial reactive demand forcing inverters into current limiting, inverter fault current limits against synchronous machines. https://doi.org/10.1038/s41467-026-76692-0
- ERCOT. NOGRR282, Large Computational Load Ride-Through Requirements, approved by the Public Utility Commission of Texas 2026-07-09, effective 2026-08-01, and Federal Energy Regulatory Commission, Order Directing NERC to File Reliability Standards Pertaining to Computational Load Integration, Docket RD26-7-000, 2026-07-16 (standards due 2026-12-31). https://www.ercot.com/mktrules/issues/NOGRR282 and https://www.ferc.gov/sites/default/files/2026-07/RD26-7-000.pdf
- 3DFS. Images and Brief Assessment from an early pilot project (VectorQ2 on a three-phase 208 volt panel. Phase currents before a demand step, uncorrected: 12.6, 12.1 and 16.3 amperes. Corrected, on a following run: 14.8, 14.3 and 14.6 amperes). Unpublished pilot record, site and date withheld. First-party.
- Sutaria, J. and Rönnberg, S. K. Propagation of Supraharmonics in a Data Center With Different Operating Modes of UPS. IEEE Access 11, 36823 to 36833 (2023). Abstract (supraharmonic emission between 2 and 150 kilohertz from power-electronic equipment). Open access. Magnitudes not asserted. https://doi.org/10.1109/ACCESS.2023.3266092
- LaCommare, K. H. and Eto, J. H. Understanding the Cost of Power Interruptions to U.S. Electricity Consumers. LBNL-55718, Lawrence Berkeley National Laboratory, 2004-09, p. xi and Figure ES-1 (national cost of power interruptions about 80 billion dollars a year, industrial customers 20.4 billion dollars, 2002 dollars, interruptions only). https://eta-publications.lbl.gov/sites/default/files/lbnl-55718.pdf
Version 3.1